
Zero Calibration
❗
- Before zero calibration, please stop the robot operation service first. You can use the APP or terminal to operate it. For more details, please refer to Connect to Robot
- After the zero calibration is done, please be sure to disassemble all the zero parts to avoid the motor from stalling and getting damaged.
The whole process of zero calibration is divided into four steps:
-
Install the mechanical parts for zero calibration;
-
Run the zero calibration program;
-
Disassemble the zero parts for zero calibration.
-
Confirm the zero position
Install the zero parts
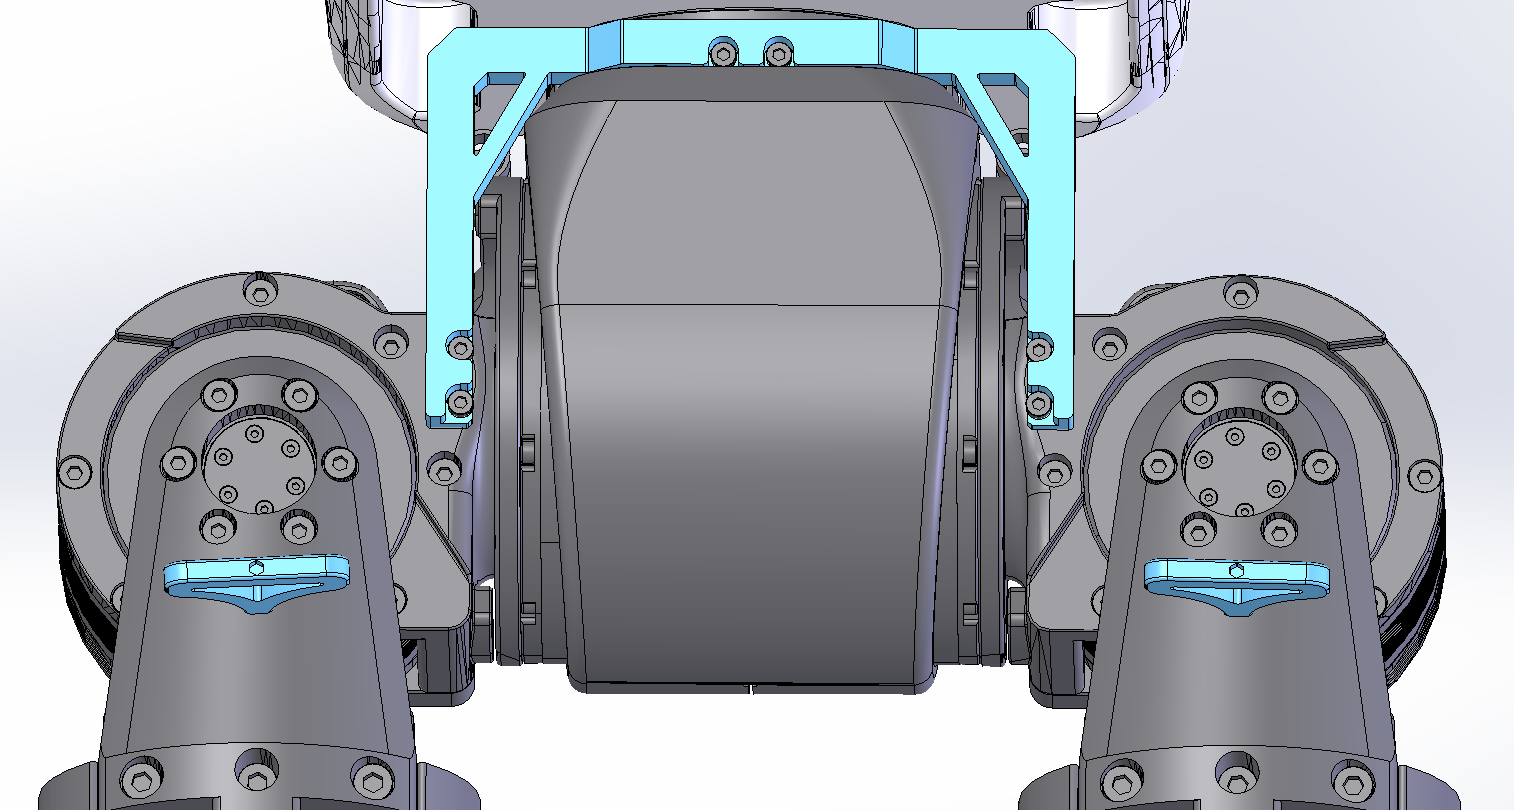
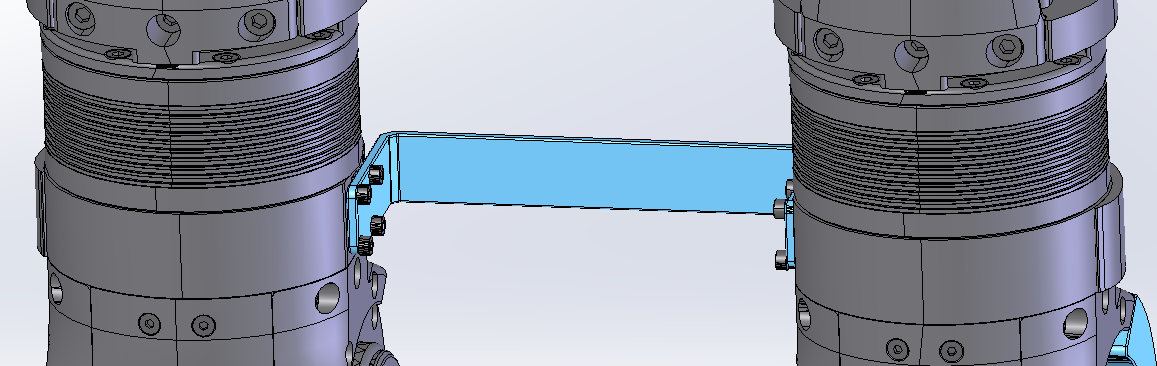
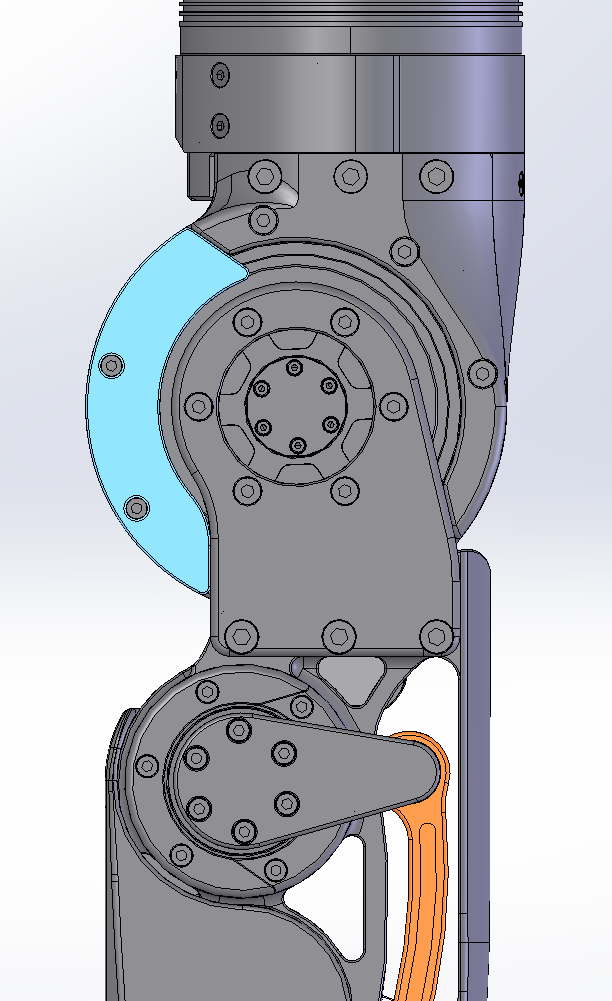
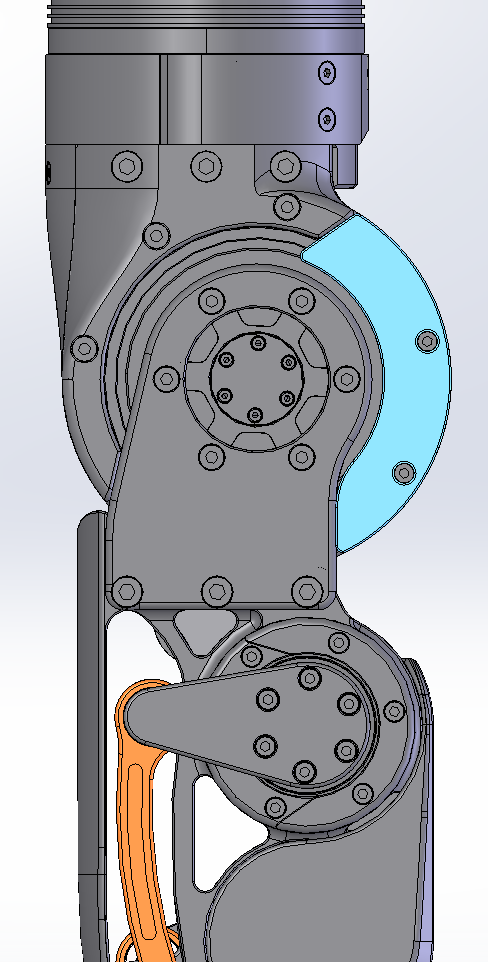
Install the zero parts marked blue on the robot according to the figure:
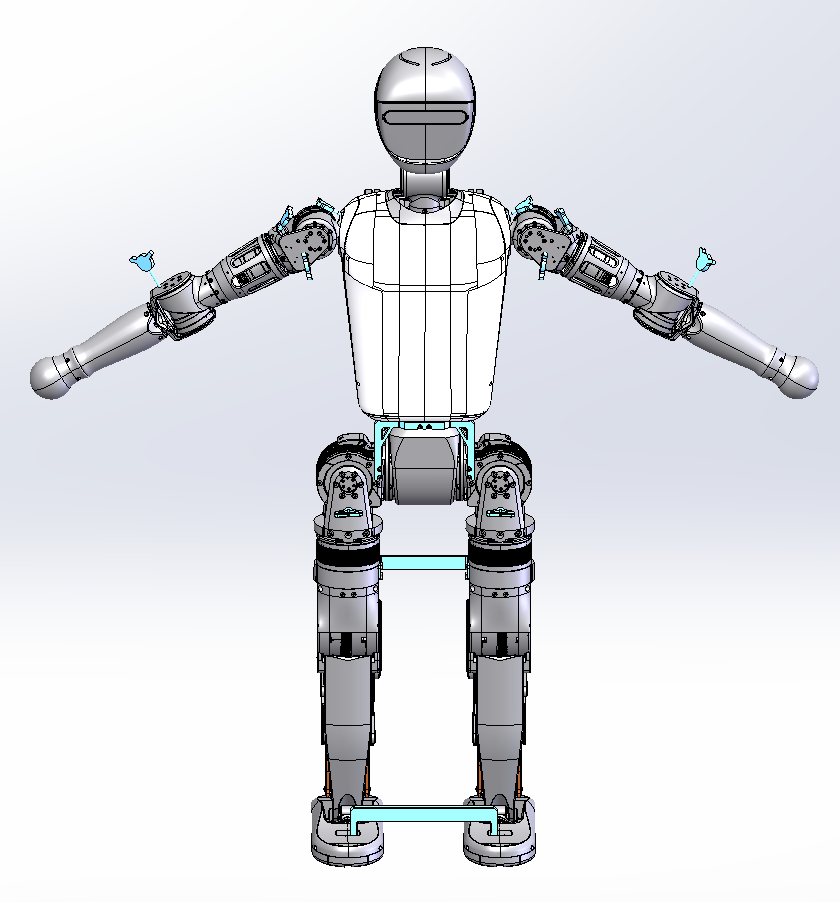
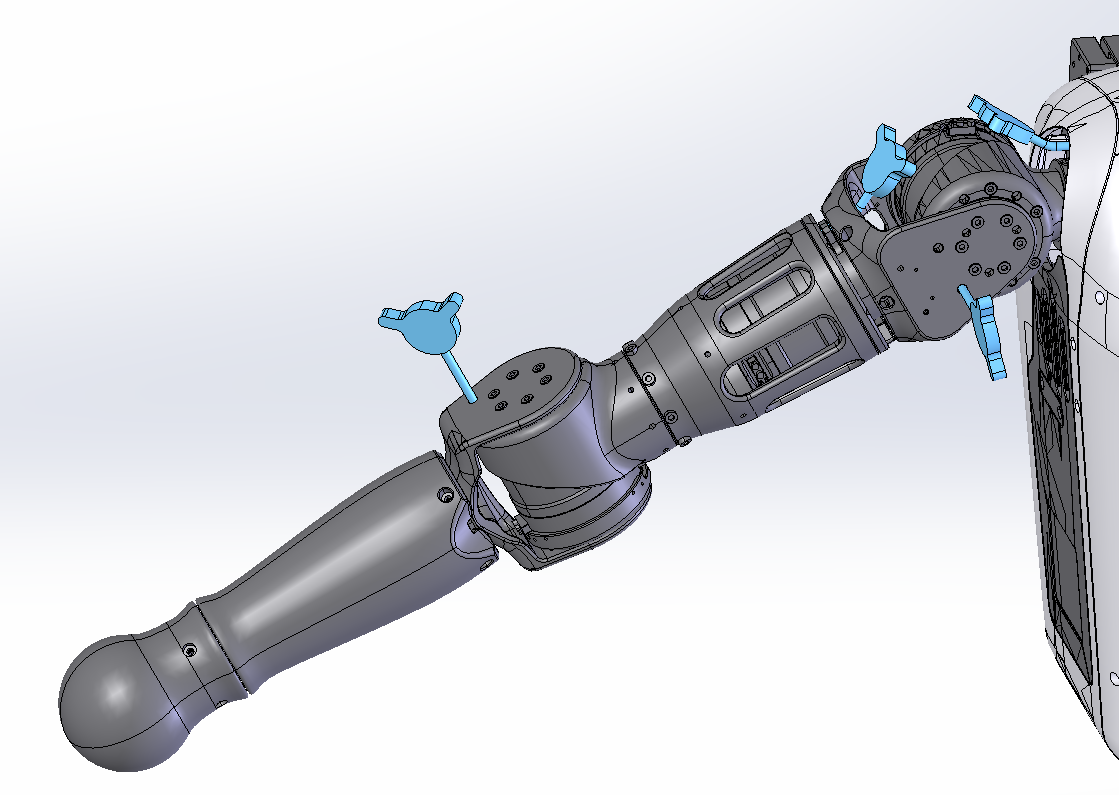
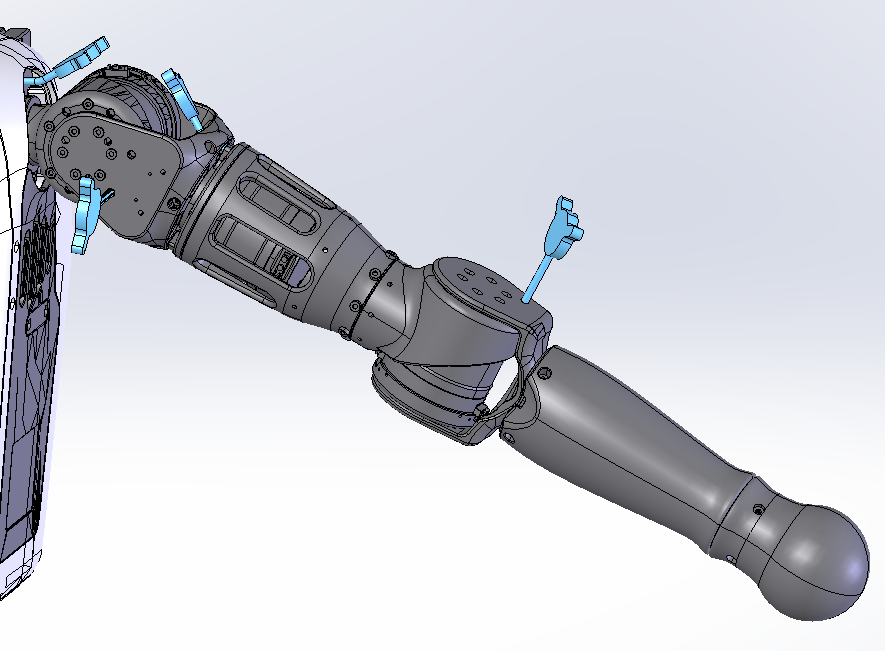
- Arm: each arm has 4 DoFs, with 4mm diameter of the pin for zero calibration. Shoulder pitch and shoulder yaw joints use curved shafts, shoulder pitch and elbow joints use straight shafts.
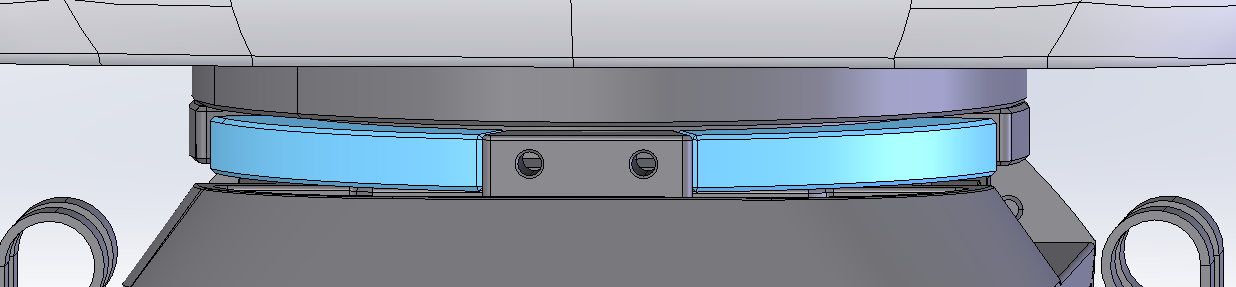
- Waist: 1 DoF, with two stoppers for zero calibration.
- Legs:each leg has 6 DoFs , with 9 parts for zero calibration. The required bolts are hexagonal cylindrical head M3×8. Remove the rubber plug from the upper shoe before foot zero calibration.
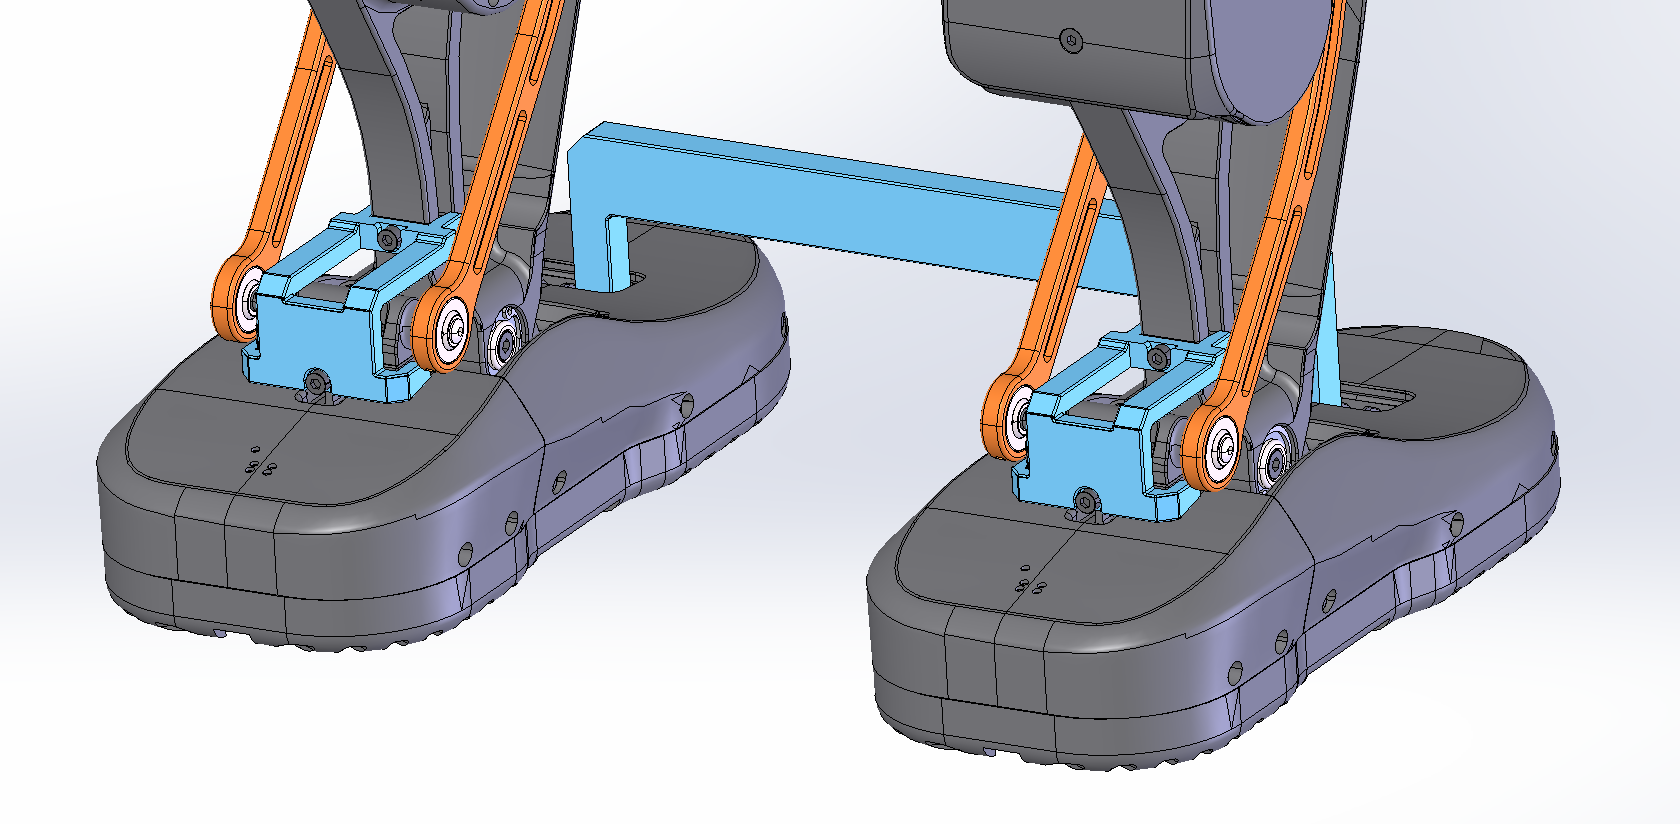
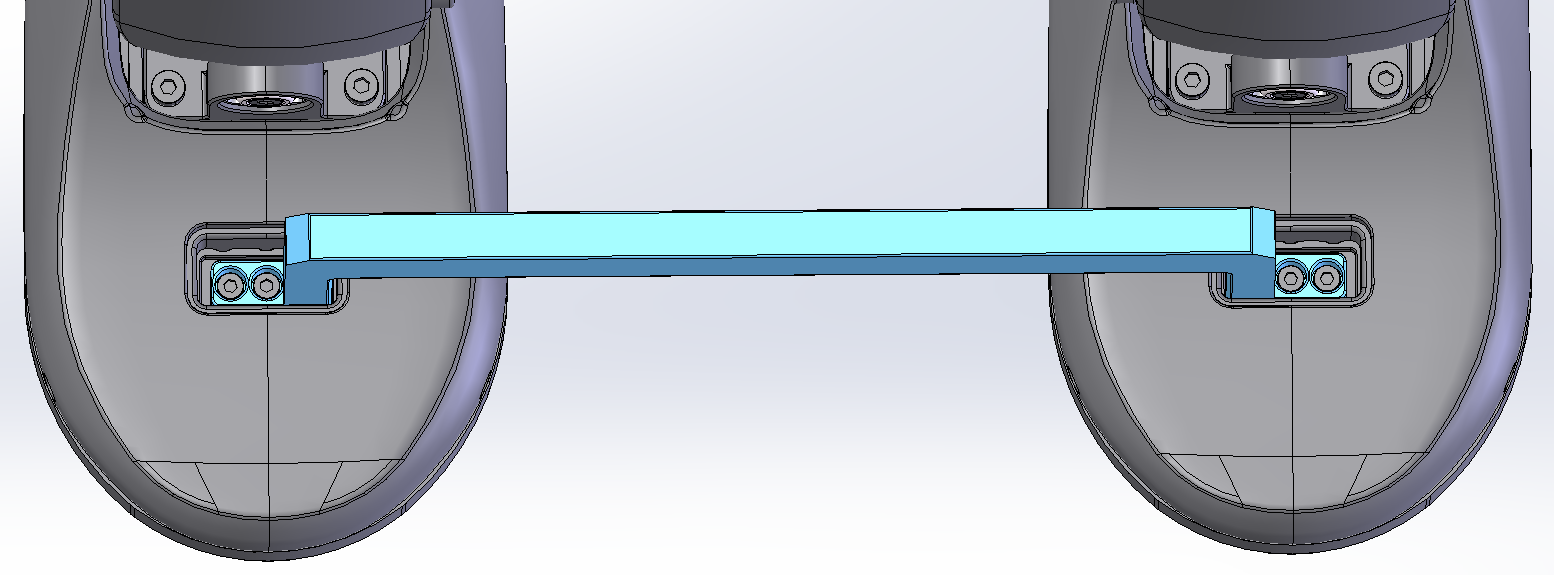
Running Zero Calibration Program
Basic
- Connect to robot on the basic board.
- Stop robot control service.
- Running zero calibration program
sudo /opt/booster/Tools/encos_reset_zero_pos_v2 all
Standard
- Connect to robot on the motion control board.
- Stop robot control service.
- Running zero calibration program
sudo /opt/booster/Tools/encos_reset_zero_pos_v2 all
Removing Zero Parts
Refer to the installation instructions and remove all zero parts in reverse order. Ensure all parts are removed before starting the robot control service to avoid joint blockage.
Confirming Zero Position
- Connect to robot.
- Start robot control service.
- Use the remote control to enter preparation mode and confirm if the robot's standing posture is normal.