
Specifications
Product Specifications
| Type | Specification Parameters | Description |
|---|---|---|
| Basic Parameters | Height (when standing upright) | 1.18m |
| Weight | About 30kg | |
| DoFs | Total DoFs | 23 |
| Single Leg DoFs | 6 | |
| Single Arm DoFs | 4(expandable) | |
| Waist DoFs | 1 | |
| Head DoFs | 2 | |
| Operational Parameters | Walking Speed | 1m/s |
| Turning Speed | 1.5rad/s | |
| Battery Parameters | Battery Life | 2h |
| Charging Time | ≤2h | |
| Cycle Life | ≥500 times | |
| Computing Platform | Basic | AGXOrin*1 |
| Standard | i7 *1 | |
| AGXOrin*1 | ||
| Sensors | Camera | Depth Camera |
| Microphone | Microphone Array | |
| Speaker | 1 | |
| Safety Fuction | Robot Emergency Stop | 1 |
| Auditory Alerts | Low Battery Alert, Joint Overheat Alert | |
| Communication Methods | Wireless Connection | WIFI 6 |
| Bluetooth | Bluetooth 5.2 | |
| Certification Standards | CE/FCC | |
| Noise | Walking Noise | ≤70dB |
| Environmental Adaptability | Environmental Adaptability | -10℃~45℃ |
| Operating Humidity | 5%~90%,without condensation |
Main parts
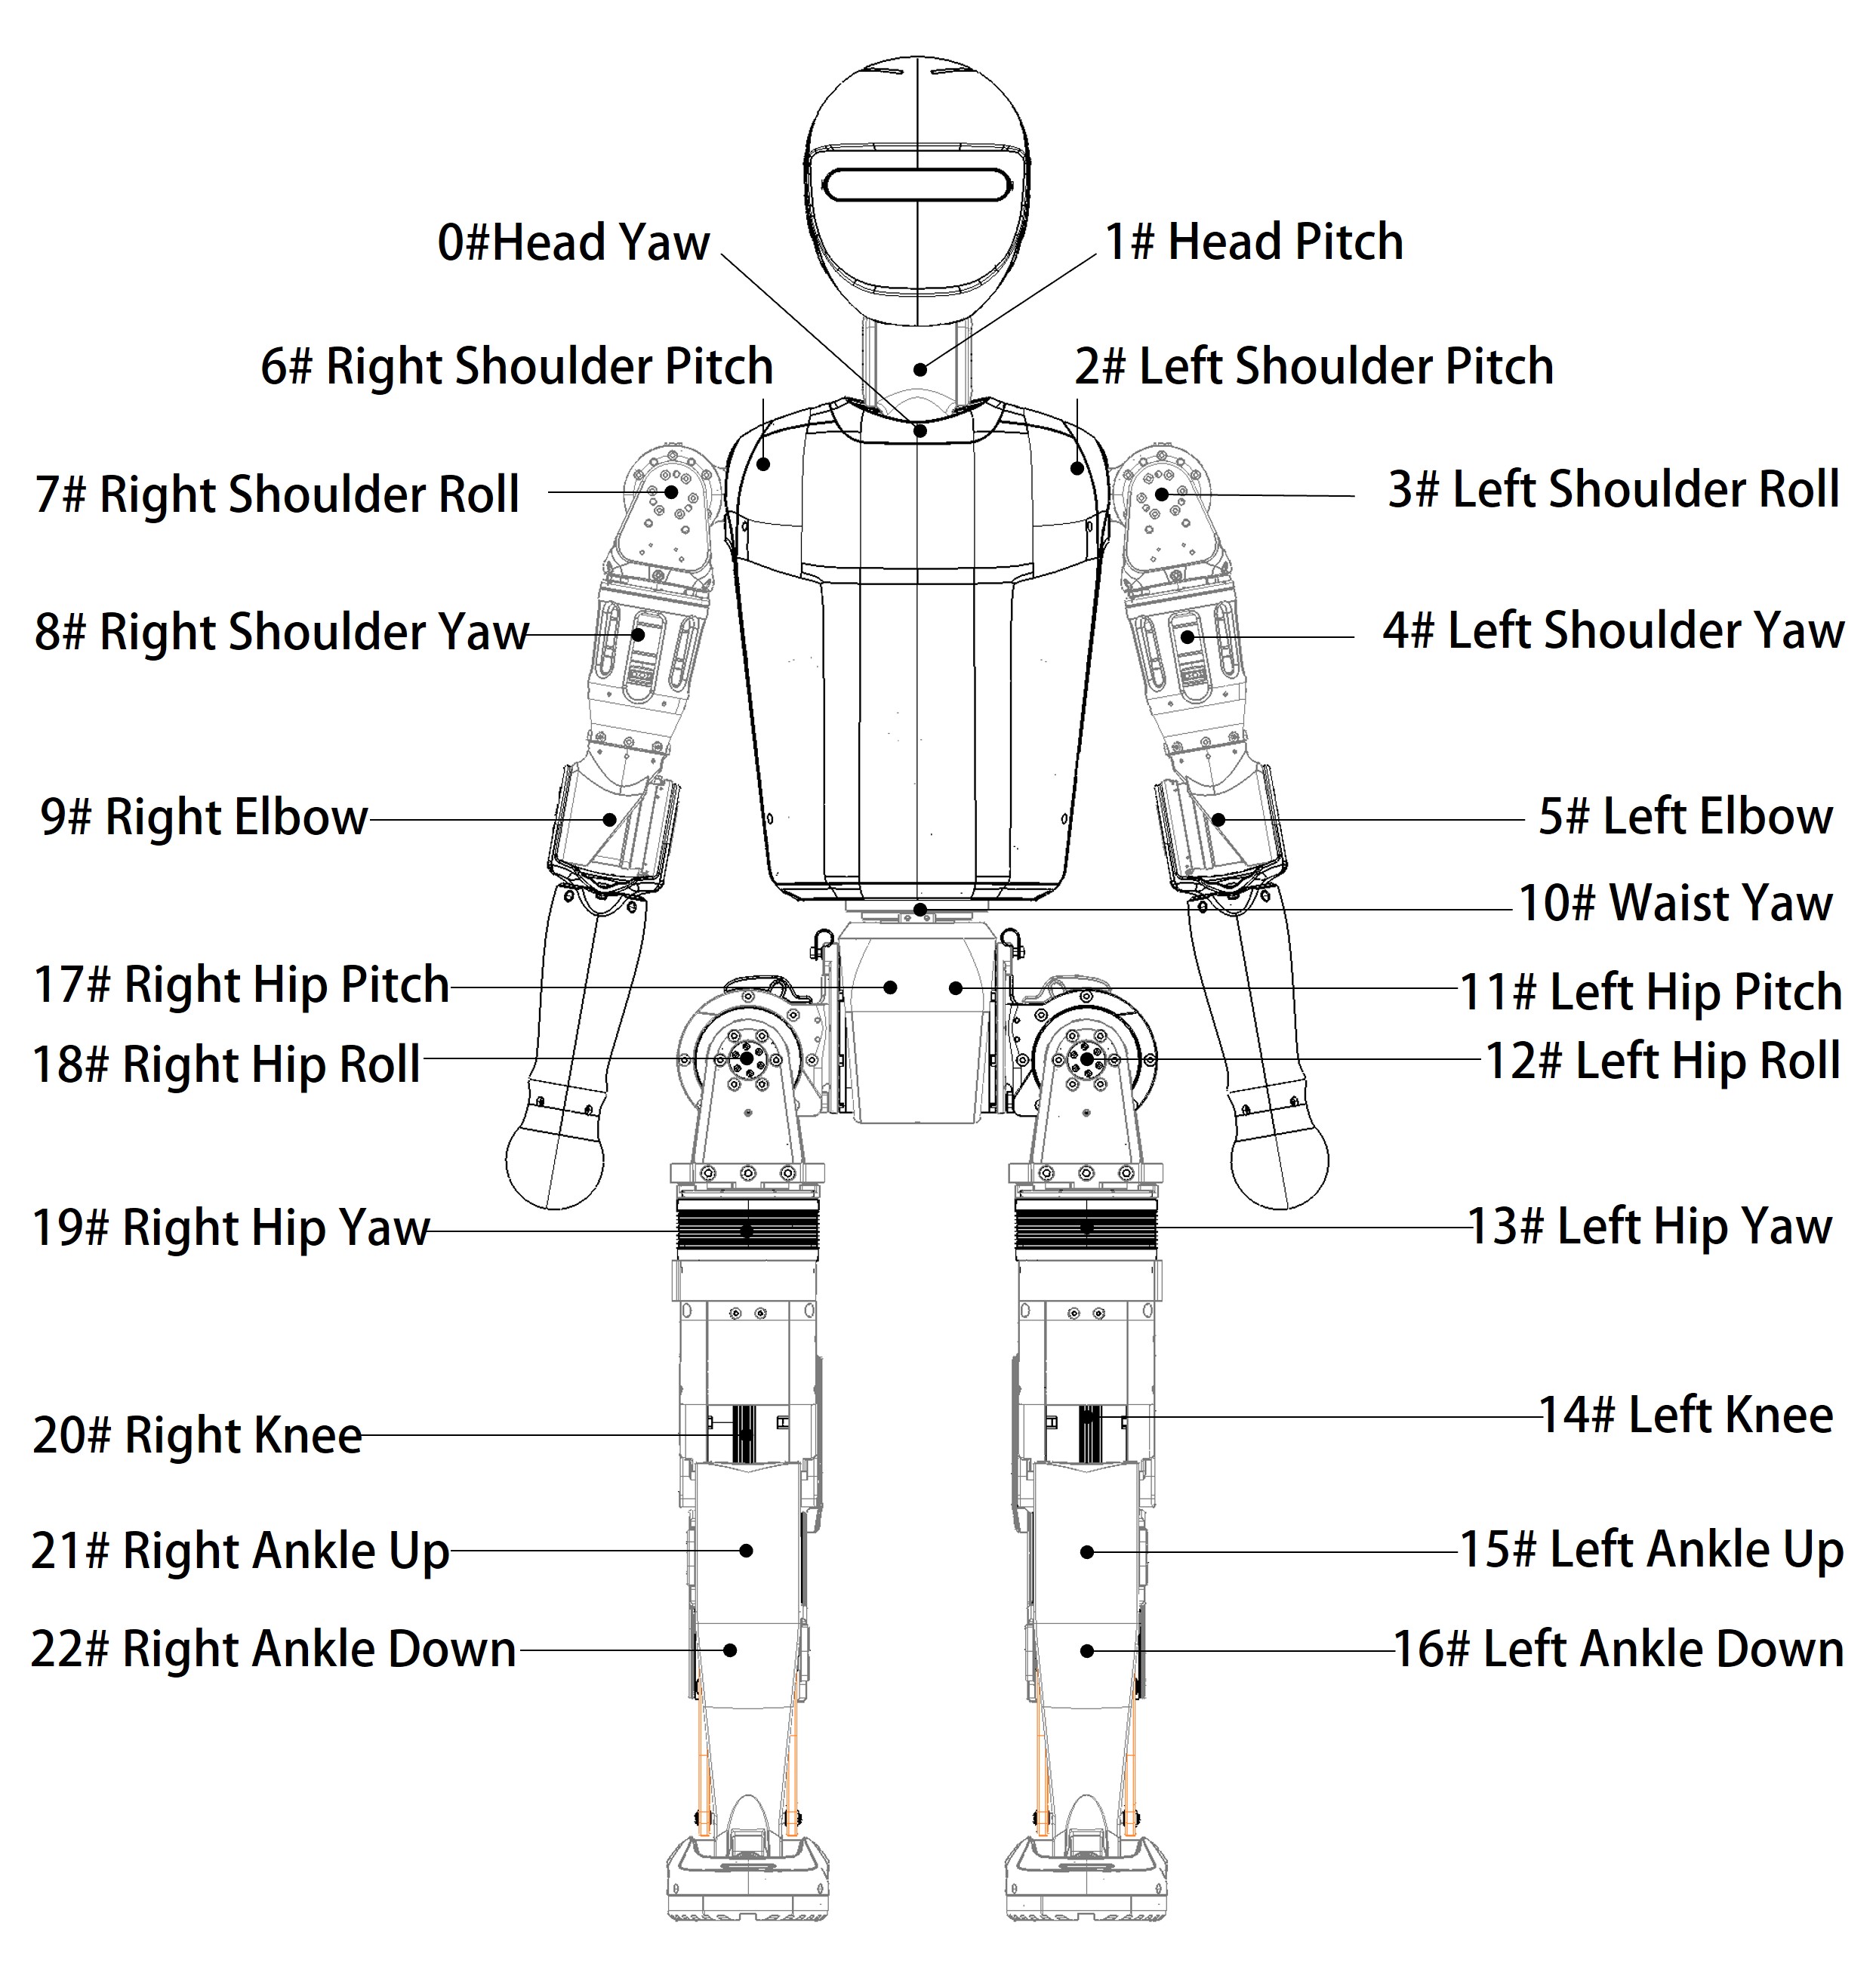
Joint motors.
Joint ID and limits.
| Joint ID | Joint Name | Limit (Degrees) | |
|---|---|---|---|
| Max | Min | ||
| 0 | Head Yaw Joint | 58 | -58 |
| 1 | Head Pitch Joint | 47 | -18 |
| 2 | Left Shoulder Pitch Joint | 68 | -188 |
| 3 | Left Shoulder Roll Joint | 88 | -94 |
| 4 | Left Shoulder Yaw Joint | 128 | -128 |
| 5 | Left Elbow Joint | 2 | -120 |
| 6 | Right Shoulder Pitch Joint | 68 | -188 |
| 7 | Right Shoulder Roll Joint | 94 | -88 |
| 8 | Right Shoulder Yaw Joint | 128 | -128 |
| 9 | Right Elbow Joint | 120 | -2 |
| 10 | Waist Yaw Joint | 58 | -58 |
| 11 | Left Hip Pitch Joint | 118 | -118 |
| 12 | Left Hip Roll Joint | 88 | -21 |
| 13 | Left Hip Yaw Joint | 58 | -58 |
| 14 | Left Knee Joint | 123 | 0 |
| 15 | Left Ankle Up Joint | 49 | -23 |
| 16 | Left Ankle Down Joint | 45 | -24 |
| 17 | Right Hip Pitch Joint | 118 | -118 |
| 18 | Right Hip Roll Joint | 21 | -88 |
| 19 | Right Hip Yaw Joint | 58 | -58 |
| 20 | Right Knee Joint | 123 | 0 |
| 21 | Right Ankle Up Joint | 49 | -23 |
| 22 | Right Ankle Down Joint | 45 | -24 |
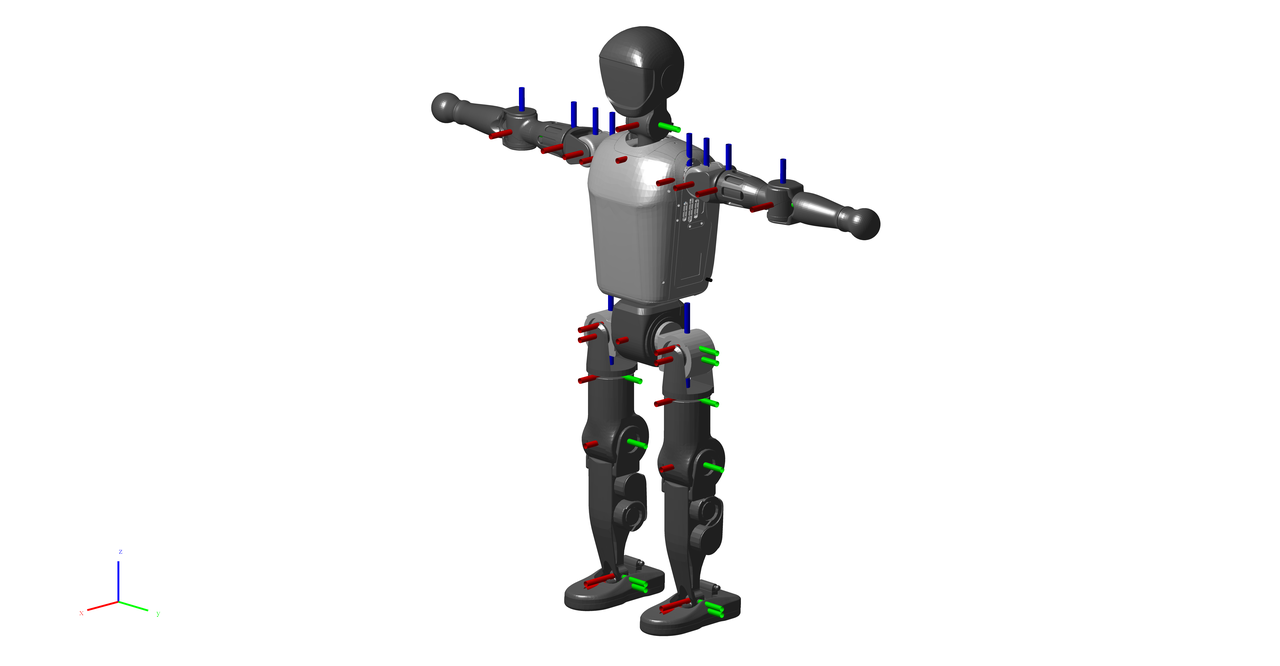
Coordinate System
The joint coordinate system with all joints at zero position is shown in the diagram below.
Controller
Version | Basic | Standard | |
Basic board | Motion control board | Perception board | |
Processor | Jetson AGX Orin 32GB | Express-i7 | Jetson AGX Orin 32GB |
Computing performance | 8-core Cortex-A78AE CPU@2GHz Tensor Cores GPU@930MHz AI performance: 200 TOPS | 6P cores + 8E cores P core maximum frequency: 4.80 GHz E core maximum frequency: 3.90 GHz | 8-core Cortex-A78AE CPU@2GHz Tensor Cores GPU@930MHz AI performance: 200 TOPS |
Memory | 32GB | 8GB | 32GB |
Storage | 512GB | 512GB | 512GB |
Wired Network | 1000M*2 | 1000M*2 | 1000M*2 |
Wireless Network | Wi-Fi 6*1 | Wi-Fi 6*1 | Wi-Fi 6*1 |
Audio | Microphone, speaker | Microphone, speaker | |
💡
- For the basic version, both the motion control program and the perception program are deployed on the basic board.
- For the standard version, the motion control program is deployed on the motion control board, and the perception program is deployed on the perception board.