
1.6.0 Firmware & App Version Release
Release Date
2026-4-18
New Features
-
Hi Chat Agent persona update
- Updated the robot's specifications and skill information in the persona
- Supports voice-triggered full-body motions such as the Michael dance
- Default persona for overseas versions changed to English
-
MJ1 + MJ2 merged into "MJ Dance"
-
Launched K1 humanoid walking/running half-body gait
-
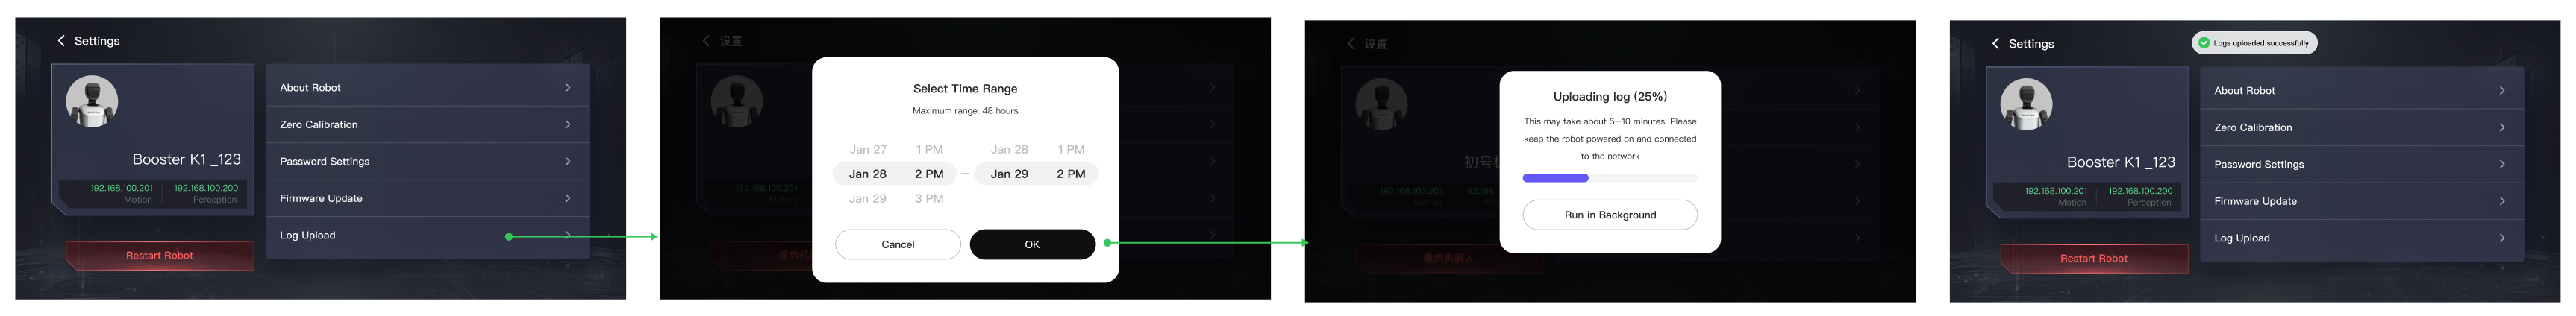
Booster App now supports one-click upload of robot logs
-
[Technical] Agent switching speed optimization
优化前 4-10s
优化后 1-2s
-
App logo redesign
-
iOS feature parity
- Supports installing and uninstalling agents
- [Open Capability] Agents now support parameter configuration
-
Supports the in-house remote controller
-
Updated low-battery prompt: added a notice that the robot will stop moving
-
Launched process management framework
-
Communication latency optimized 11ms -> 9ms
-
Autonomous kicking changed to power kicking
-
Launched audio service and accompanying SDK API
- Compatible with Lunqu ring microphone and in-house ring microphone
- Supports multi-source audio mixing, allowing multiple processes to play sound simultaneously
- Supports playback and recording of mainstream audio formats (pcm, mp3, wav)
- Supports capturing raw microphone audio streams
- Supports capturing noise-reduced audio streams [in-house ring microphone]
- Supports sound source localization [in-house ring microphone]
-
SDK added interfaces related to lion dance motions
-
Supports enabling/disabling joint feedback filtering via configuration
-
Supports enabling/disabling low-battery mode via configuration (For RoboCup)
-
Unified communication topics across different camera models (resolves the issue of user programs needing different topics to run on different robot models)
-
Hardware adaptation: supports the use of INNFOS joints for head joints
Bug Fixes
- Fixed the issue of excessively long Agent switching time, reducing it to around 2s
- Fixed the issue where the K1 needed to raise its head when switching between walking/running gait and kicking motions
- Fixed the issue of missing mesh file information in the ROS topic /robot_description
- Fixed the issue of discontinuous ROS TF messages
- Fixed the issue of missing frame in camera ROS messages
- Fixed the issue where the motion control program crashed after enabling motion control data recording